I am Spok, and I build robots.
When I got involved with my high school robotics team, I became enamoured with the prospect of designing complex physical systems controlled by intelligent algorithms. Since then, I’ve shared my passion as a lead of many tech groups, as a teaching assistant at the University of Toronto, and as a founder of the campus’s own robotics club. By the end of my studies, I became very excited about machine learning as well, and I focused my Masters degree on the intersection of the two. I am currently refining my skills by developing service robots at Admetal Robotics, though I am constantly looking for new avenues to apply my knowledge.
PublicationsMEng in Robotics Engineering, 2023
University of Toronto
HBSc in Computer Science, 2020
University of Toronto
PREVIOUS ASSOCIATIONS THAT HELPED DEVELOP MY SKILLS
Compiled 19 documents into an expected format within 1h, saving an estimated 100 engineering hours.
Wrote a highly customizable Python script for translating data between a SQL database and Microsoft Office files to automate over 40% of all current engineering processes through a web interface.
Purchased and configured LLM development and deployment server for generating intent vectors for requirements, while handling company apps (OpenWebUI and NextCloud). This sped up mapping and grouping tasks by up to 80% while automating repetitive tasks for a team of 17 people.
Created a Python script for converting and verifying thousands of nuclear requirements into grouping, mapping, and review pipeline. The workflow allowed a team of 11 to finish 90% faster, saving 300 hours.
Led, mentored, and worked with a team of three on the following:
Developed a player-following golf trolley with gesture control, ball tracking, and obstacle avoidance features using YOLOv11, a stereo camera, UWB, and an RK3588 chip. The system ran in a 18Hz loop and was able to follow a player for a full golf game without failures despite temporary missed detections.
Fine-tuned and tested OpenVLA and RDT-1B on pick-and-place, sorting, and fine manipulation tasks for a 6-DoF arm and the LeapHand in order to train and deploy service robots in the real world.
Deployed and modified DexCap, Robot Telekinesis, and LeapHand systems for teleoperation and data collection. The LeapHand system was teleoperated to collect over 60h of fine manipulation data.
Built, trained, and tested UMI for few shot learning on fine manipulation tasks with a 6-DoF arm.
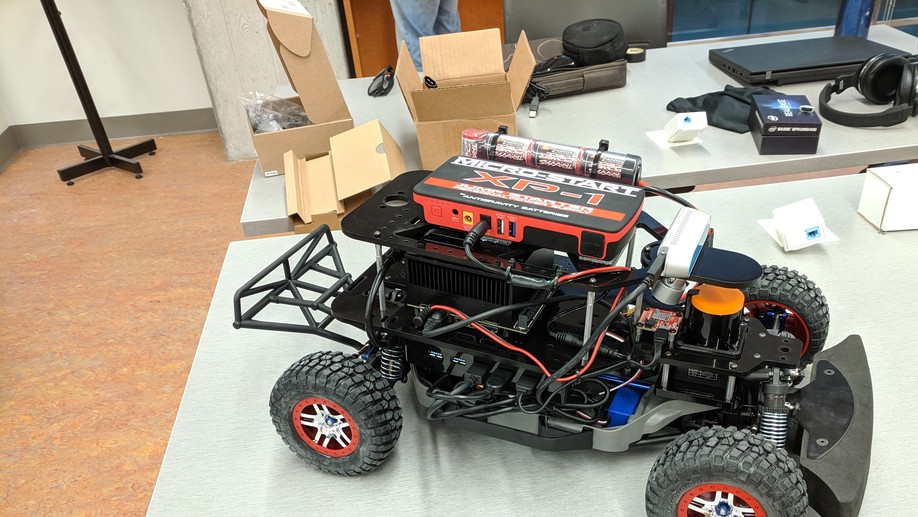
Built and programmed an autonomous mobile base with ROS2, a LiDAR, and a depth camera, capable of mapping, localizing in, and safely traversing unknown environments.
Created an embodied autonomous assistant framework for one-armed service robots using ChatGPT, YOLOv8, and voice networks interfacing with a custom API and running on a Jetson AGX Xavier.
Used TensorRT to run YOLOv5 and PyDnet on a Jetson Nano for real-time human position tracking in 3D space using a single camera. The system ran at 9Hz and tracked up to 10m with a 50cm accuracy.
Created, developed, and maintained a part-locating program for pick-and-place systems used by 3 clients. The system used a single overhead camera with a Raspberry Pi running OpenCV and Python to locate parts with 2mm accuracy.
Implemented SLAM with sensor fusion to allow a restaurant delivery robot to navigate indoor environments autonomously with 0 failures.
Led tutorials, assisted during lectures, held office hours, prepared course materials, marked tests and assignments, and taught the following skills:
Led tutorials, assisted during lectures, held office hours, prepared course materials, marked tests and assignments, and taught the following skills:
Led tutorials, assisted during lectures, held office hours, prepared course materials, marked tests and assignments, and taught the following skills:
Led tutorials, assisted during lectures, held office hours, prepared course materials, marked tests and assignments, and taught the following skills: